Research
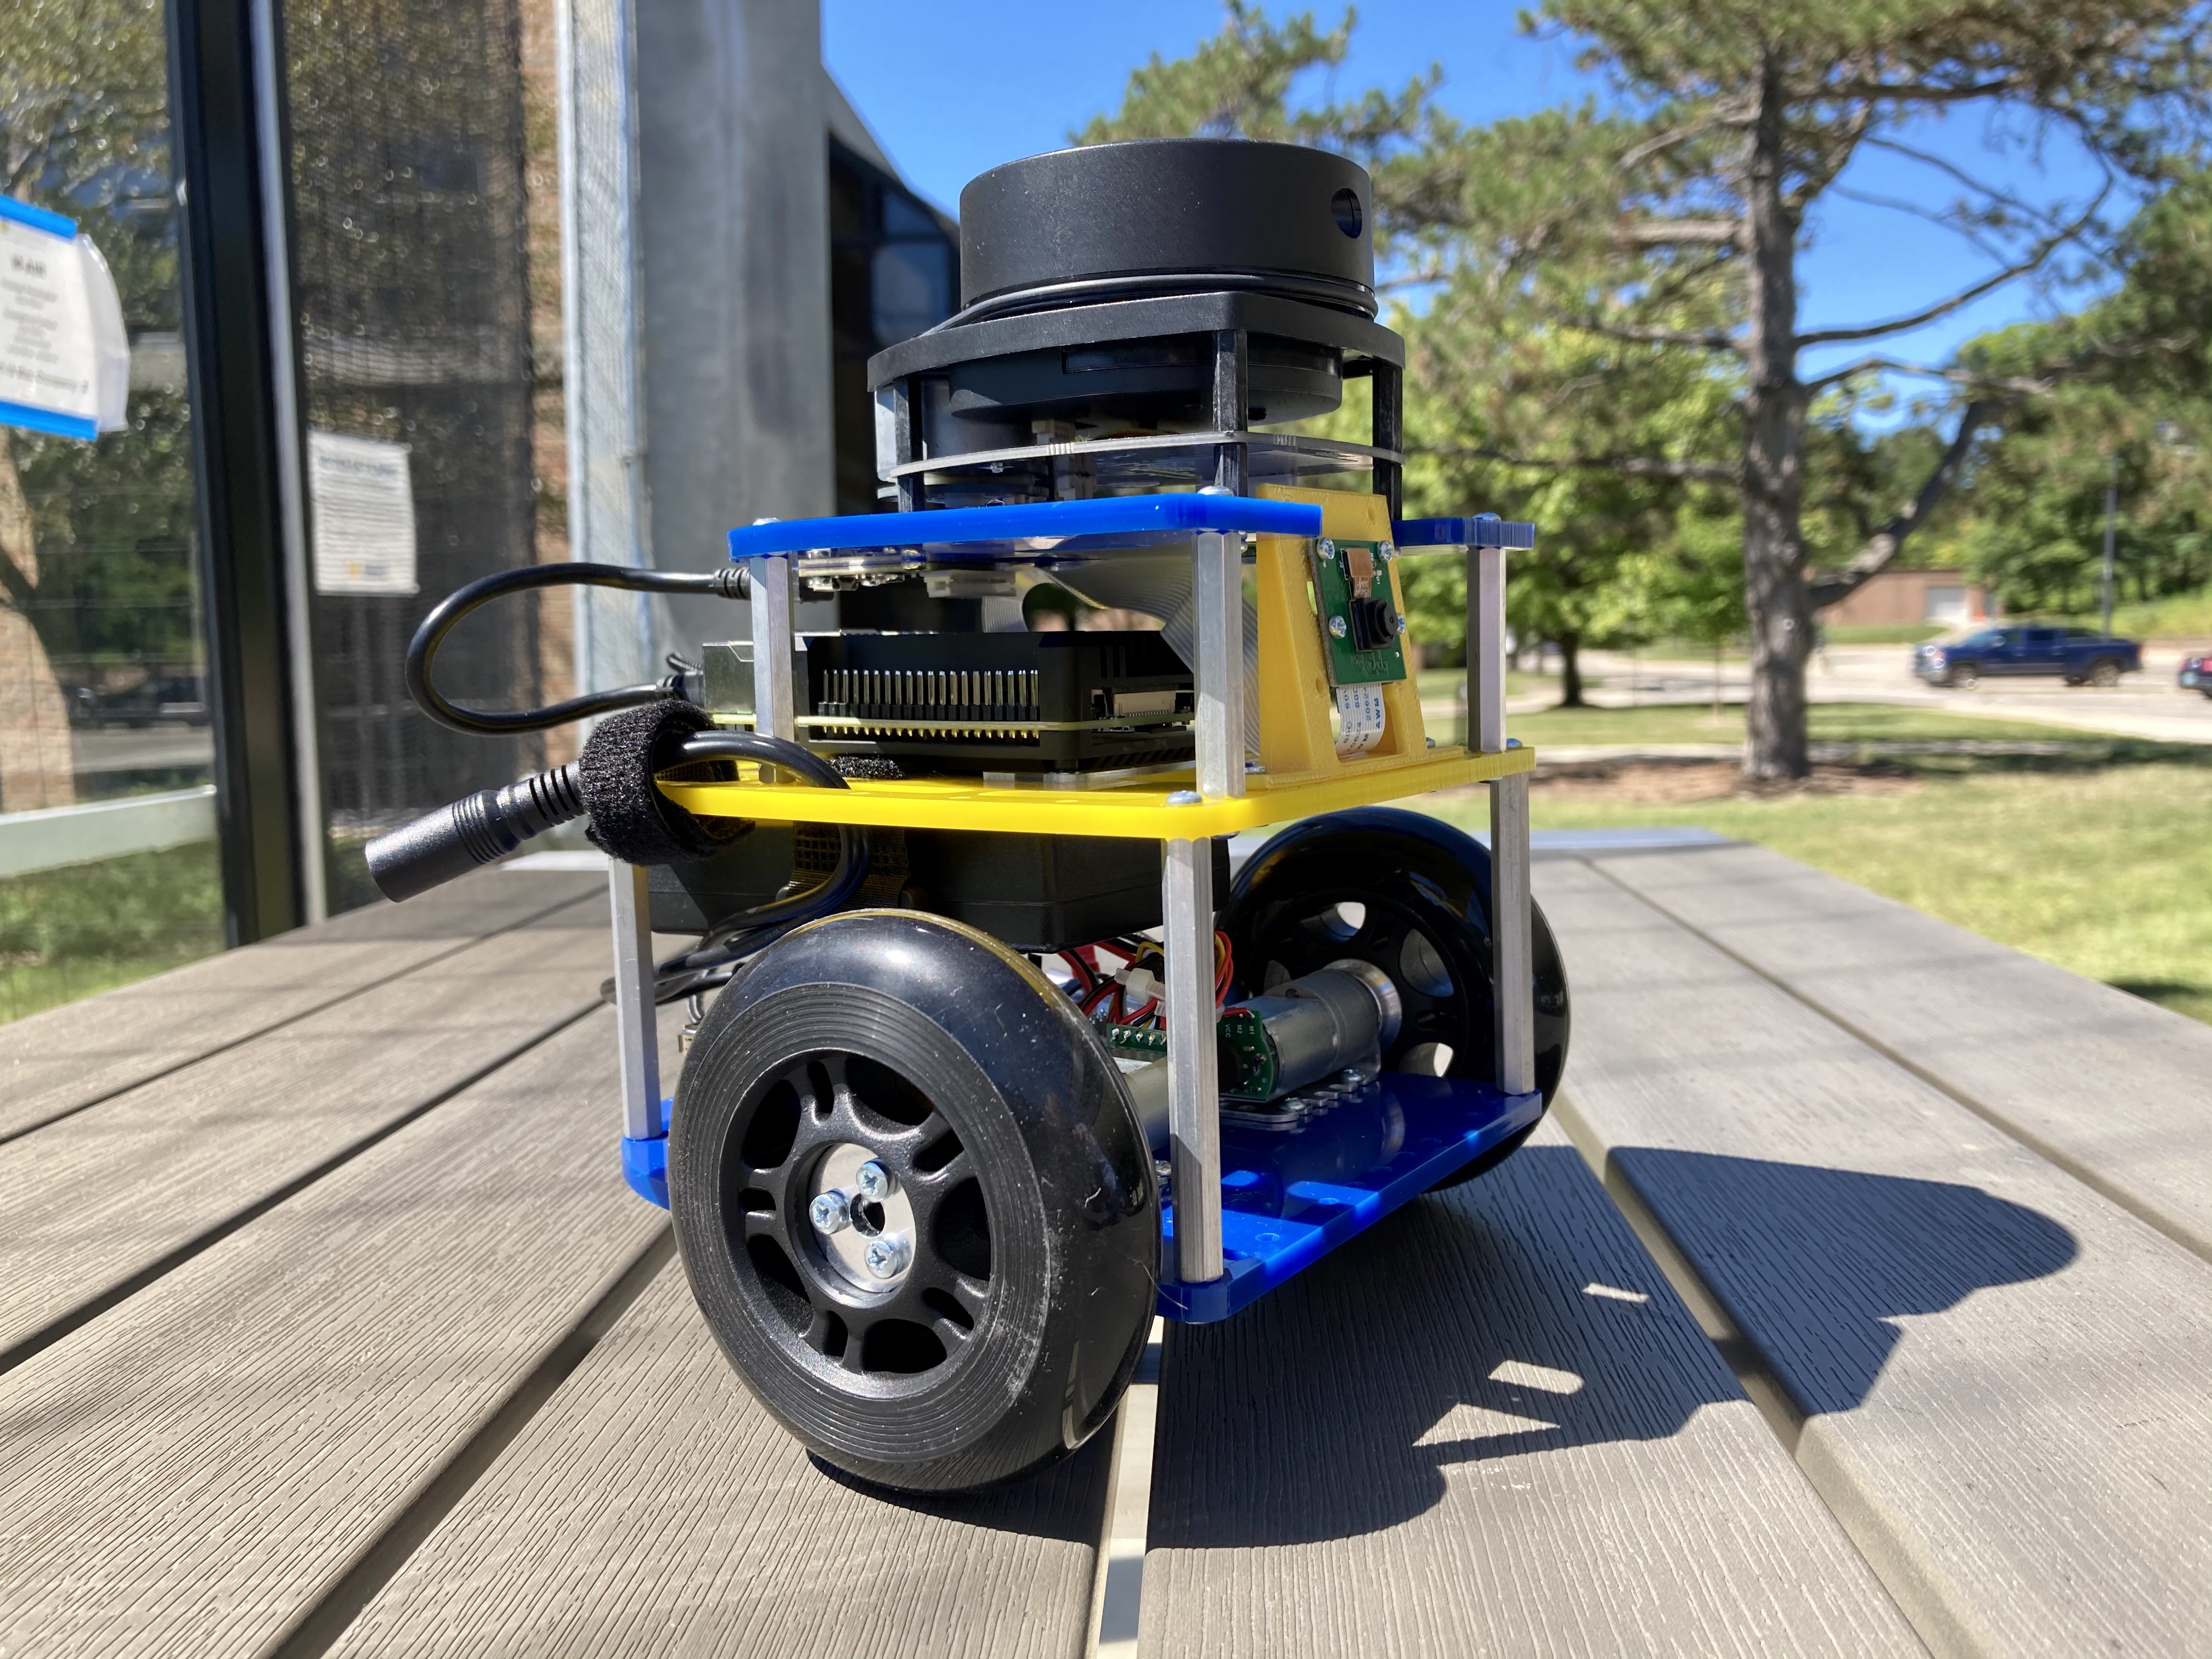
Autonomous MBots
My work with MBots focused on motion analysis and real-time safety. I used wheel encoder data to examine velocity and acceleration accuracy, and analyzed the results to better understand how the robots behaved over time in a practical setting.
This was part of my research work in the MARVL Lab. I helped with computer vision and the lower level state estimation used to inspect and discuss robot motion relative to their environment.